Robotic Perception / Industrial Computer Vision
Industry & robotics · Northern Navarre (Confidential client)
Computer vision for industrial robotics
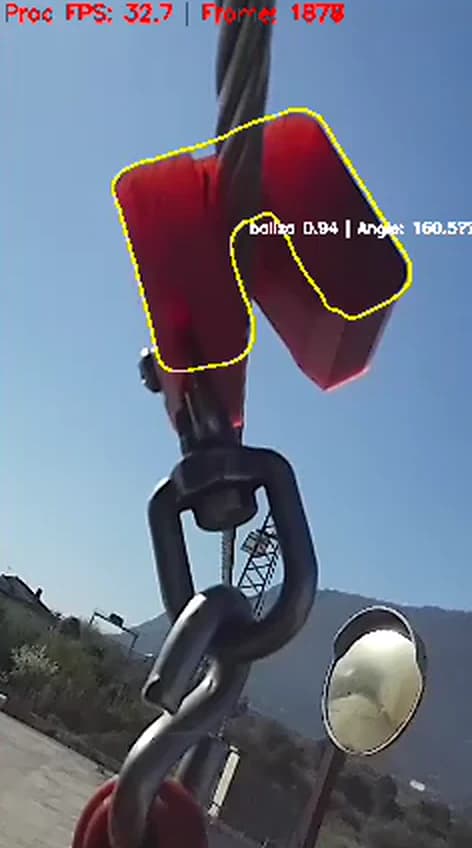
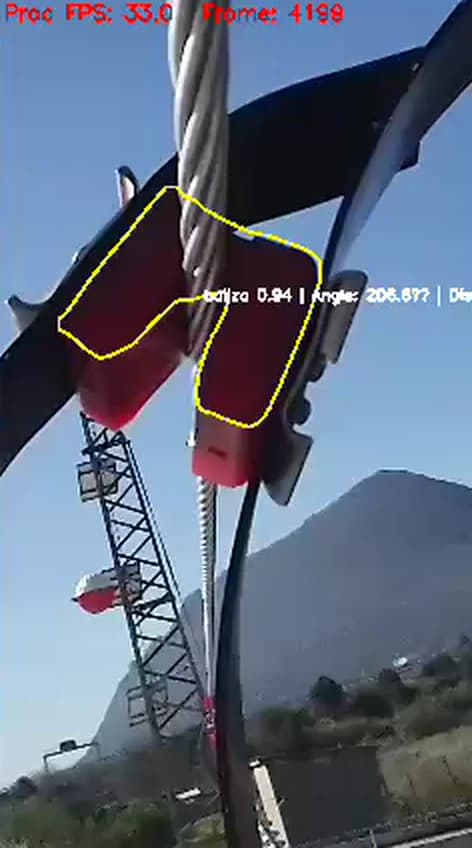
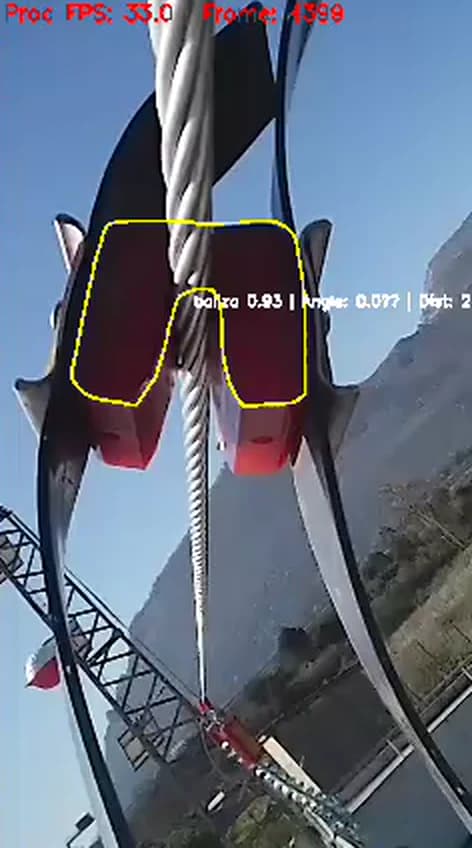
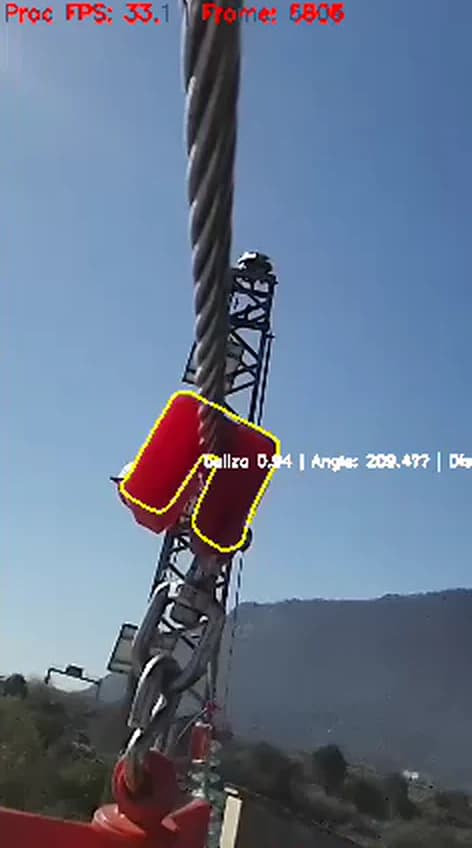
- Camera
- Detection
- Spatial information
- Robotics integration
The challenge
At an industrial robotics company in northern Navarre, a robot needed to perceive its environment in order to interact with the elements on the line.
What we did
We developed a computer vision solution that identifies the elements and their positions so the robot can interact with them.
How it works
The camera captures the scene. The model detects objects and estimates their position. That information is passed to the robotic system to support the defined task.
Technologies
Python · Computer vision · OpenCV · Deep learning · Robotics
Result
The robot identifies and locates the elements to interact with them autonomously.
Validation depends on the task, objects and operating conditions. The result described here applies to this project's scope.