INDUSTRIAL AI · PHYSICAL AI
Physical AI: intelligence for the physical world
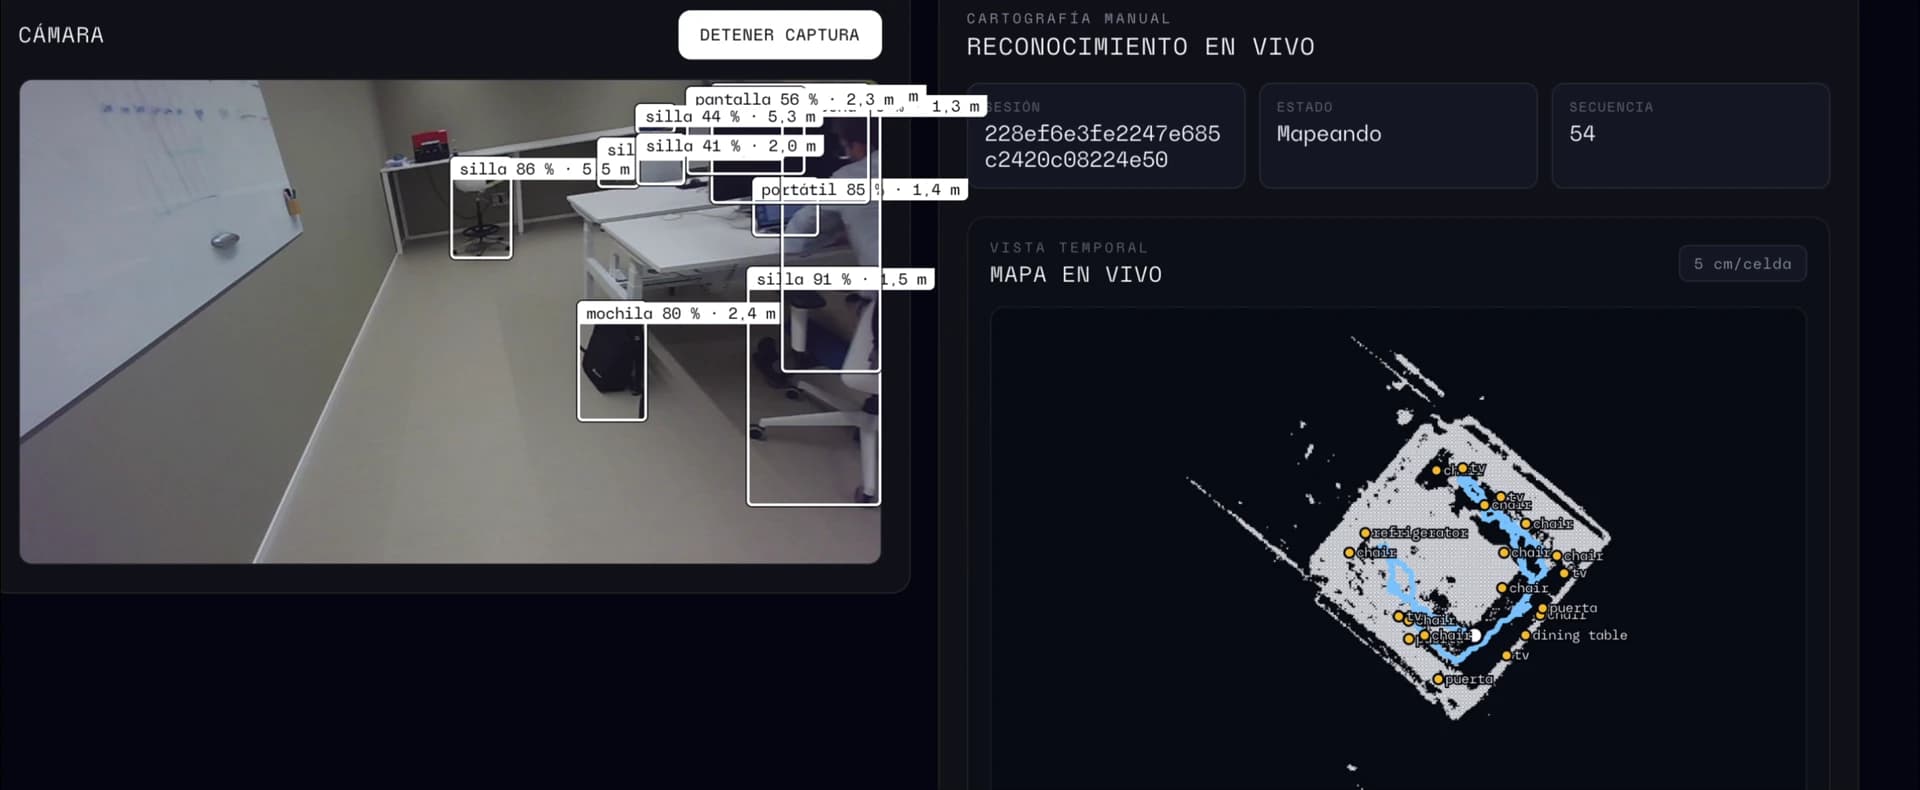
We develop software that connects what a robot perceives with what it needs to do. We integrate vision, language and data into robotic platforms and industrial systems.
Perceive, interpret and respond
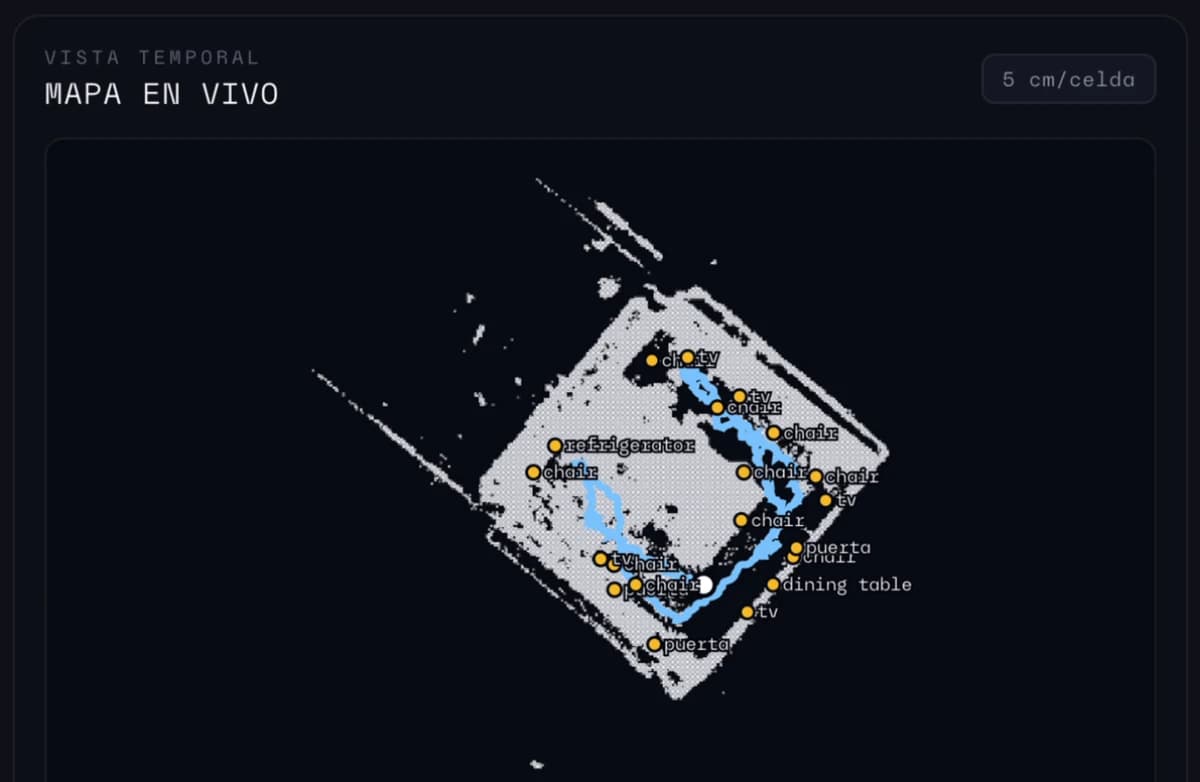
Recognising a part, locating a person and answering a question require different capabilities working together. Physical AI connects those capabilities to sensors, software and physical mechanisms. Our role is to develop and integrate the intelligence each application needs.
From sensing to responding
- Perceive
Capture signals from the environment using cameras and other sensors.
- Understand
Interpret objects, information and context.
- Reason
Evaluate information and options within the system’s boundaries.
- Act
Integrate a response with the available interfaces and mechanisms.
Each application has a different scope. We define which stages to automate and where human oversight is needed.
Solutions
From recognising a part to talking with a visitor. We build the intelligence and software that connect perception, information and action.
Physical AI & Robotics
Perception, navigation and interaction on existing robotic platforms.
Industrial Computer Vision
Recognise objects and locate parts using cameras and visual data.
Human-Robot Interaction
Voice, language and context for more natural interaction with robots.
Industrial AI & Edge
AI models connected to your operational data and equipment.
Physical AI in our projects
See how we approach perception for industrial robotics and combine navigation, voice and knowledge in TXISTU, the humanoid guide for Polo IRIS.